Joined the National University of Singapore to study for an MSc in Robotics.
Gang
Yang
MSc Robotics
National University of Singapore
EMBODIED AI / VLN / SPATIAL INTELLIGENCE
Building intelligent agents thatcan perceive, reason, move, andinteract with the physical world.
I am an MSc Robotics student at the National University of Singapore. My research sits at the intersection of embodied AI, multimodal vision-language models, spatial intelligence, and robot learning.
I build benchmarks, learning systems, and interactive experiences that connect visual reasoning with physical action — from global-scale urban navigation to tangible mixed-reality systems.
I enjoy travelling, hiking, fitness training, and guitar. These pursuits bring balance, energy, and new perspectives to my life, while keeping me open-minded, resilient, and curious.
Embodied AIVision-Language NavigationMultimodal LLMsRobot Learning
SCROLL TO EXPLORE ↓01
News
WalkerBench was accepted to ECCV 2026.
Forest Remix was accepted to the International XR Metaverse Conference.
02
Publications
01
ECCV 2026
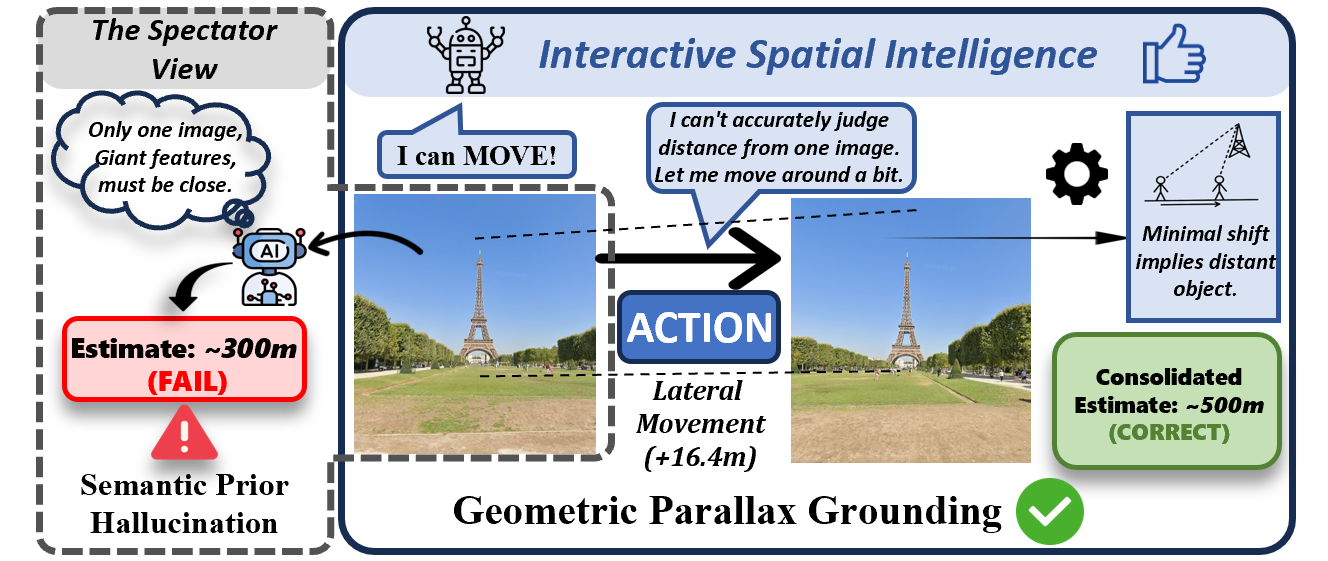
Stand Up and Move: Benchmarking Interactive Spatial Intelligence in WalkerBench
* Equal contribution
02
UNDER REVIEW
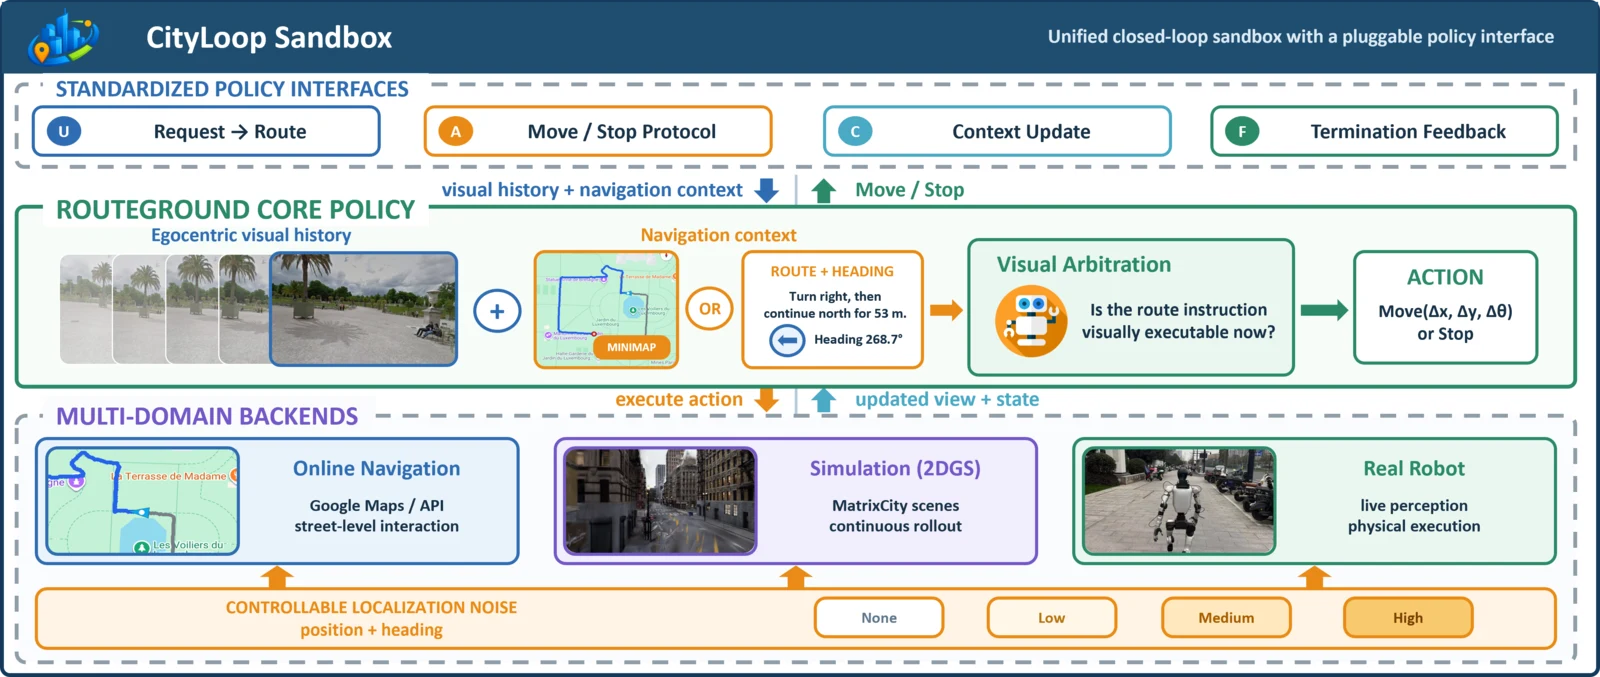
CityLoop: Sandbox for Tool-Grounded Urban Navigation
03
XRM 2026
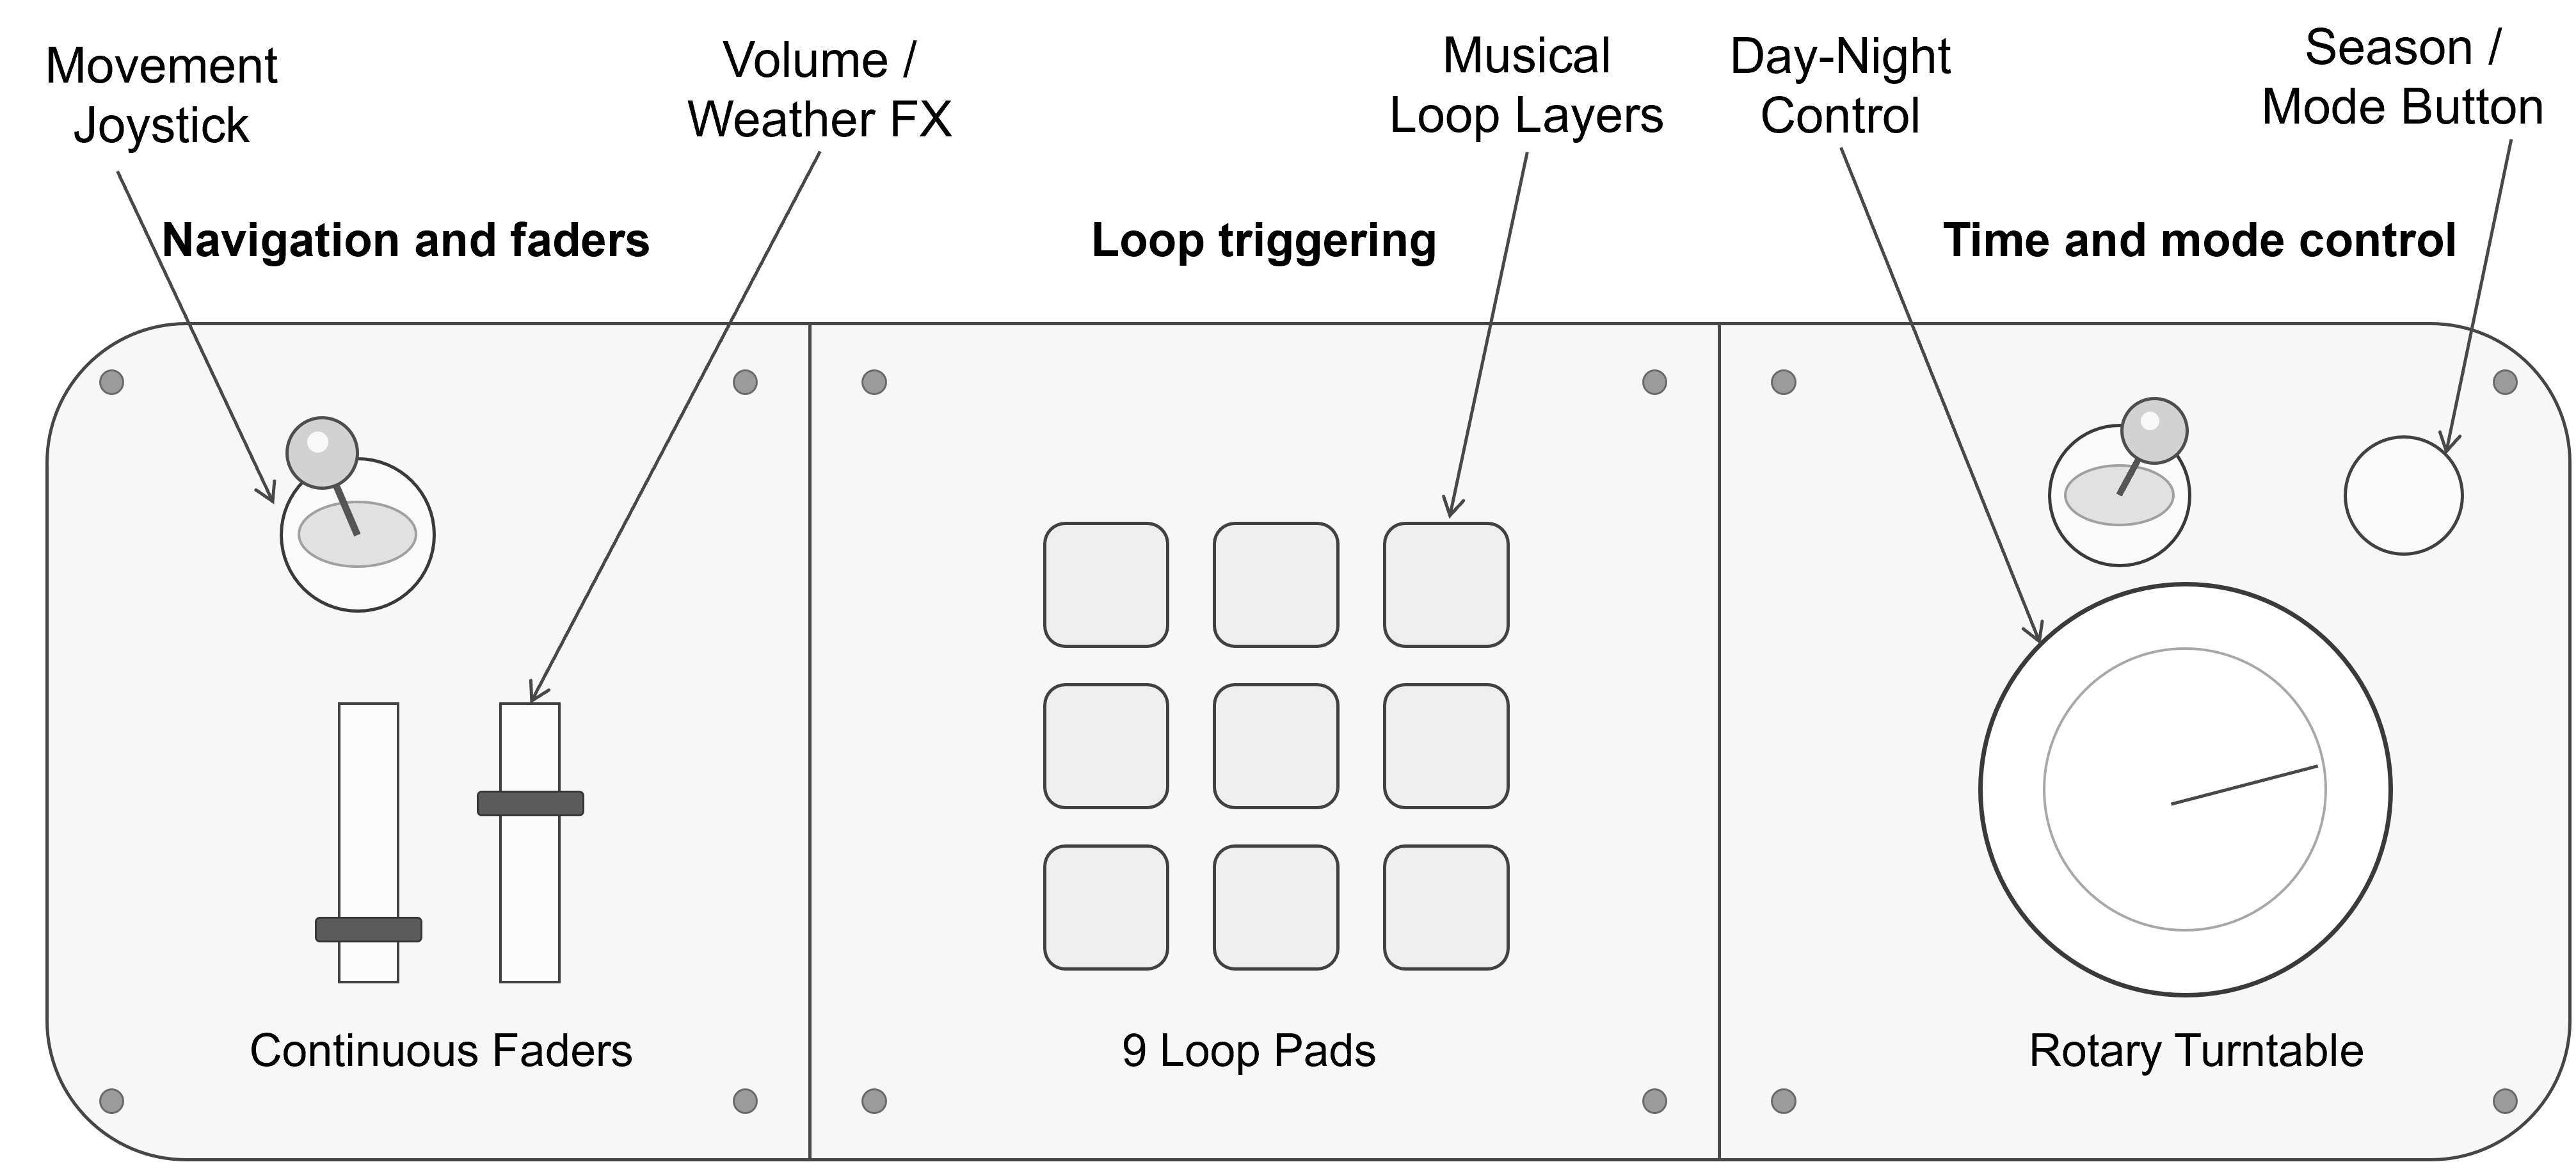
Forest Remix: A Musical Forest with Custom Embodied Tangible Hardware
* Equal contribution, listed alphabetically
03
Education
National University of Singapore
MSc in Robotics
University of Nottingham
BSc (Hons) in Computer Science · First-class
04
Research Projects
CityLoop
Tool-Grounded Urban Navigation with Vision-Language Models
A request-to-arrival urban navigation sandbox connecting online navigation, 2D Gaussian Splatting simulation, and real-world robot deployment through a shared policy interface.
CityLoop
Tool-Grounded Urban Navigation with Vision-Language Models
- Built CityLoop, a request-to-arrival urban navigation sandbox that unifies online navigation, 2DGS simulation, and real-world robot deployment through a shared move/stop policy interface.
- Constructed an evaluation corpus spanning 43 cities and 22 countries/regions, with 1,000 routes, 500 POI requests, 5,000+ Street View panorama walking-route samples, and controlled position/heading perturbations.
- Developed RouteGround by fine-tuning Qwen3-VL-4B with counterfactual tool-vision conflict training and a four-stage curriculum, improving medium-noise keypoint decision accuracy from 24.9% to 59.0%, reaching 58.0% 2DGS closed-loop success and 6/20 zero-shot robot successes.
WalkerBench
Interactive Spatial Intelligence Benchmark
A global-scale benchmark spanning 161 cities across six continents, with 1,000 tasks covering active perception and spatial navigation.
WalkerBench
Interactive Spatial Intelligence Benchmark
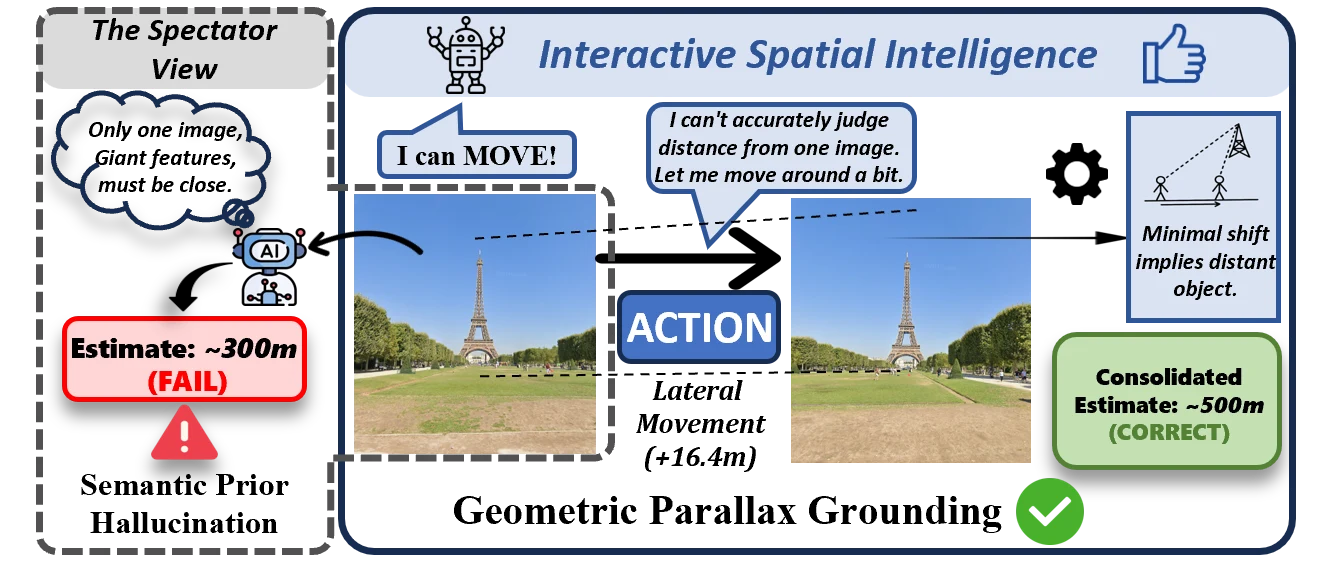
- Built WalkerBench, a global-scale interactive benchmark for embodied spatial intelligence spanning 161 cities across 6 continents, with 1,000 tasks covering Active Perception and Spatial Navigation.
- Implemented Spatial-IDE, a training-free framework that combines Explicit Topological Memory (ETM) with cognitive decoupling to address long-horizon spatial forgetting in VLM-based agents.
- Achieved average benchmark gains of +18.49 points to 36.66% (+104.97% relative) across 9 VLMs and demonstrated zero-shot transfer to real-world urban navigation on a Unitree G1 robot.
Forest Remix
Embodied XR Music System
An open-world musical forest that connects a custom 3D-printed physical controller with procedural visual and spatial audio feedback in Unreal Engine 5.
Forest Remix
Embodied XR Music System
- Directed a 6-person cross-functional team in developing a UE5-based Mixed Reality experience; owned system architecture, Git workflow, and task allocation for an open-world musical forest system.
- Developed a custom 3D-printed physical controller using Raspberry Pi Pico 2 W and MicroPython; implemented low-latency input mapping through UE5 Enhanced Input.
- Used UE5 Blueprints and MetaSound to translate physical actions into procedural feedback, dynamically driving visual environmental shifts and spatial audio modulation.
ANN-enhanced MPC
Intelligent Control for Power Converters
Neural-network-assisted model predictive control for renewable-energy power converters, validated through system simulation and hardware-in-the-loop testing.
ANN-enhanced MPC
Intelligent Control for Power Converters
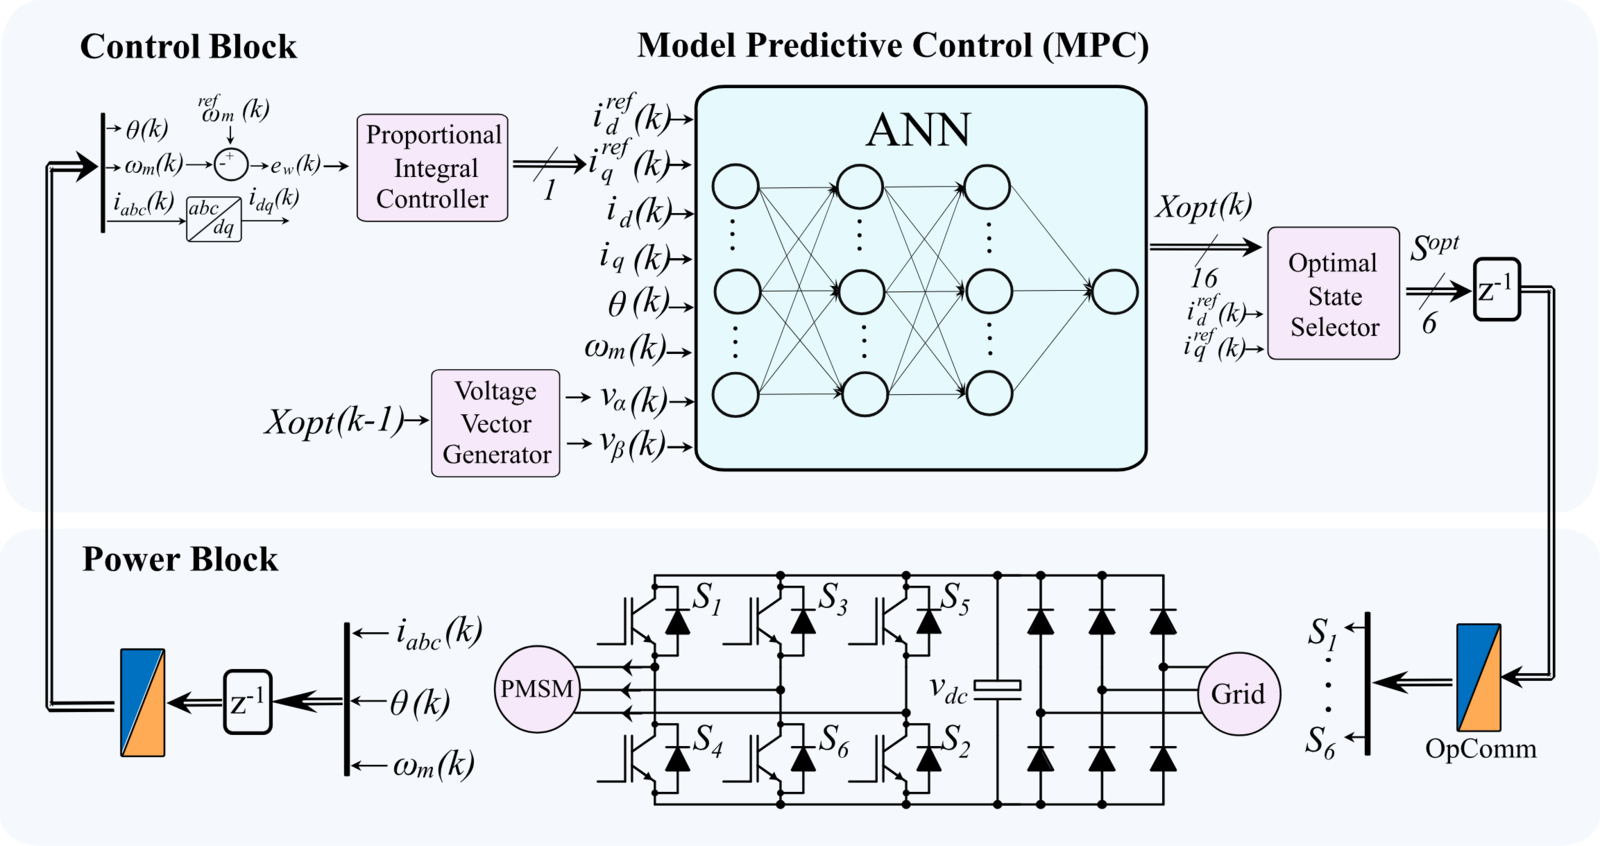
- Designed and optimized AI-enhanced Model Predictive Control algorithms for power converters in renewable energy systems, improving real-time performance and efficiency.
- Developed and trained a neural network achieving 93% prediction accuracy, enabling rapid inference and reliable real-time decision-making in embedded control environments.
- Conducted system-level modelling and simulation in Matlab/Simulink, validating results through Hardware-in-the-Loop (HiL) testing on FPGA/DSP hardware platforms.
VR Rehabilitation Game
Immersive Lower-Limb Rehabilitation Platform
A VR rehabilitation platform integrating gamified lower-limb training with treadmill hardware, adaptive navigation, and intelligent NPC interaction.
VR Rehabilitation Game
Immersive Lower-Limb Rehabilitation Platform
- Designed and implemented a VR-based rehabilitation platform using Unreal Engine, integrating gamified training with treadmill hardware for lower-limb recovery.
- Built advanced VR-human interaction systems, including a dynamic visualization dashboard and adaptive smart minimap to enhance usability and immersion.
- Developed an intelligent NPC behavior system with Behaviour Trees, enabling dynamic pathfinding and adaptive difficulty in rehabilitation exercises.
05
Professional Experience
Research Intern, Embodied AI
Unitree Robotics · Hangzhou, China
Research Intern, Embodied AI
Humanoid Robot Navigation in Open Environments
- Led the development of a closed-loop humanoid robot navigation system for natural-language-driven, long-horizon navigation in open environments, integrating maps and external tools, first-person visual perception, and vision-language model decision-making across online environments, 2D Gaussian Splatting (2DGS) simulation, and deployment on a Unitree G1 robot.
- To address spatial-state forgetting during long-horizon operation and inconsistent decisions under noisy observations, developed explicit spatial memory and active perception mechanisms together with tool–vision conflict training, improving navigation decision accuracy under medium noise from 24.9% to 59.0%.
- Built a data-generation and closed-loop evaluation pipeline that continuously produces navigation tasks, trajectories, and perturbed scenarios, enabling rapid iteration of navigation policies across online maps and 2DGS simulation while reducing the cost of real-robot validation.
- Completed long-distance zero-shot navigation in real urban environments on the Unitree G1; parts of this work contributed to WalkerBench (ECCV 2026) and CityLoop (under review).
Research Assistant
PEMC Group, University of Nottingham · Nottingham, UK
Research Assistant
Neural-Network-Enhanced Model Predictive Control
- To address the high computational cost of online prediction and switching decisions in conventional FCS-MPC, built a closed-loop simulation system for permanent-magnet synchronous motor (PMSM) drives and investigated neural networks for current prediction and switching-state decision-making.
- Designed and compared two feedforward neural network (FNN) controllers—one based on intermediate current prediction and the other on end-to-end switching decisions—and used class balancing and noise perturbation to improve robustness to minority switching states and measurement noise.
- Integrated the neural-network controllers into a MATLAB/Simulink motor-control loop and systematically evaluated tracking error, dynamic response, and computational cost. The best-performing design achieved a current RMSE of approximately 0.30 A and a settling time of approximately 0.41 s, with closed-loop performance broadly matching conventional FCS-MPC.
Data Mining Intern
Ping An Insurance · Ningbo, China
Data Mining Intern
- Engineered a multi-point user tracking pipeline for the Haochezhu app, enabling granular monitoring of user interactions within the insurance purchase flow.
- Utilized SQL-based ETL processes for large-scale data cleaning and feature extraction, eliminating anomalous records and ensuring robust downstream analytics.
- Conducted A/B experiments on UI/UX elements, leading to a 21% increase in click-through rate (CTR) and 6% growth in conversion rate for cross-sell products.